Ecosystem & Applications
Explore tactile simulation and dexterous manipulation demos, then find project source code and integration guides.
Application Demos
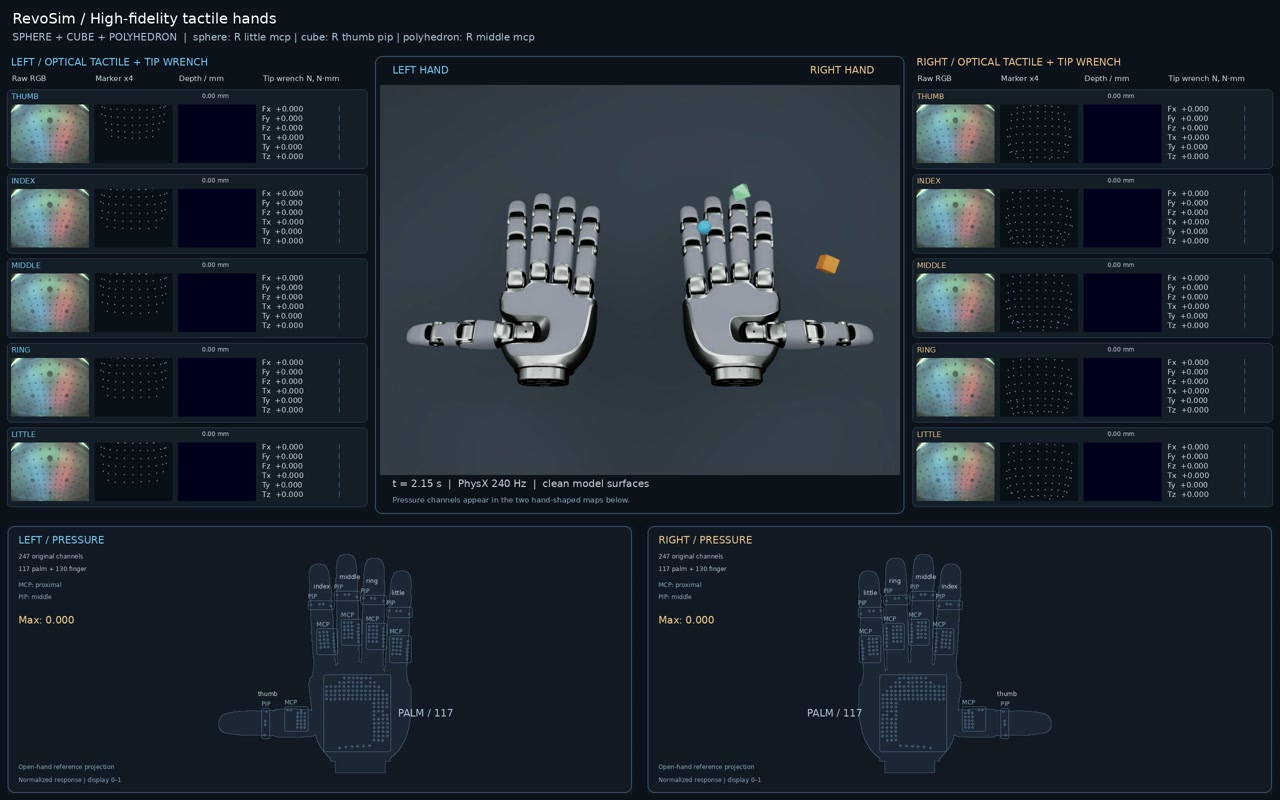 Simulation · Touch
Full-Hand Tactile Simulation
Explore RevoSim bimanual simulation, fingertip visuotactile sensing, whole-hand piezoresistive responses, and sensor data.
Explore Tactile Simulation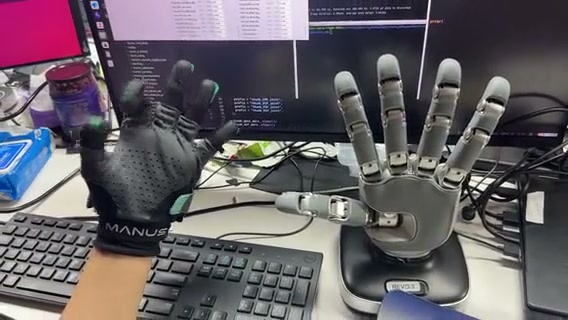 Real Robot · Simulation
Algorithm Demos
Browse the complete collection of retargeting, reinforcement learning, imitation learning, and tactile demos by category.
Browse Algorithm DemosExplore ecosystem workflows: simulation, data, models, and touch →
Simulation & Learning
RevoSim (Tactile Simulation)
Find environment requirements, installation steps, and Python examples for open-source full-hand tactile simulation.
View Source & Installation ↗
RevoLab (Reinforcement Learning)
Load USD assets, configure task environments, and run reinforcement learning examples in NVIDIA Isaac Lab.
View Isaac Lab Guide →
Robot Integration
Unitree G1 Adaptation
Hardware mounting, electrical connection, serial communication, and ROS 2 control setup for the Unitree G1 humanoid robot.
View G1 Guide →
Revo 1 Arm Integration (Chinese)
Find examples and integration instructions for Revo 1 with a six-DoF robotic arm.
View Integration Guide →
Revo 2 Arm Integration (Chinese)
Find examples and integration instructions for Revo 2 with a six-DoF robotic arm.
View Integration Guide →
Teleoperation & Data Collection
BrainCo Motion Capture Glove
Capture hand poses and map them to the robot hand, with connection and control examples.
View Integration Guide →
Manus Data Glove (Chinese)
Map human hand motion from Manus gloves to the robot hand for teleoperation.
View Integration Guide →
BrainCo EMG Armband
Use an EMG armband to recognize gestures and control the hand, with setup and runtime examples.
View Integration Guide →
BCIGo Neuro-Telemetry
Connect BCIGo EEG/EMG signals and send processed control commands to the dexterous hand.
View Control Example →