Overview
BrainCo Revo 1 is a biomimetic dexterous hand with 6 active joints and 10 degrees of freedom. Its public hardware variants are Revo 1 Basic and Revo 1 Advanced; tactile sensing depends on the SKU. Its maximum hand load is 30 kg, and its five-finger grip force is 50 N.
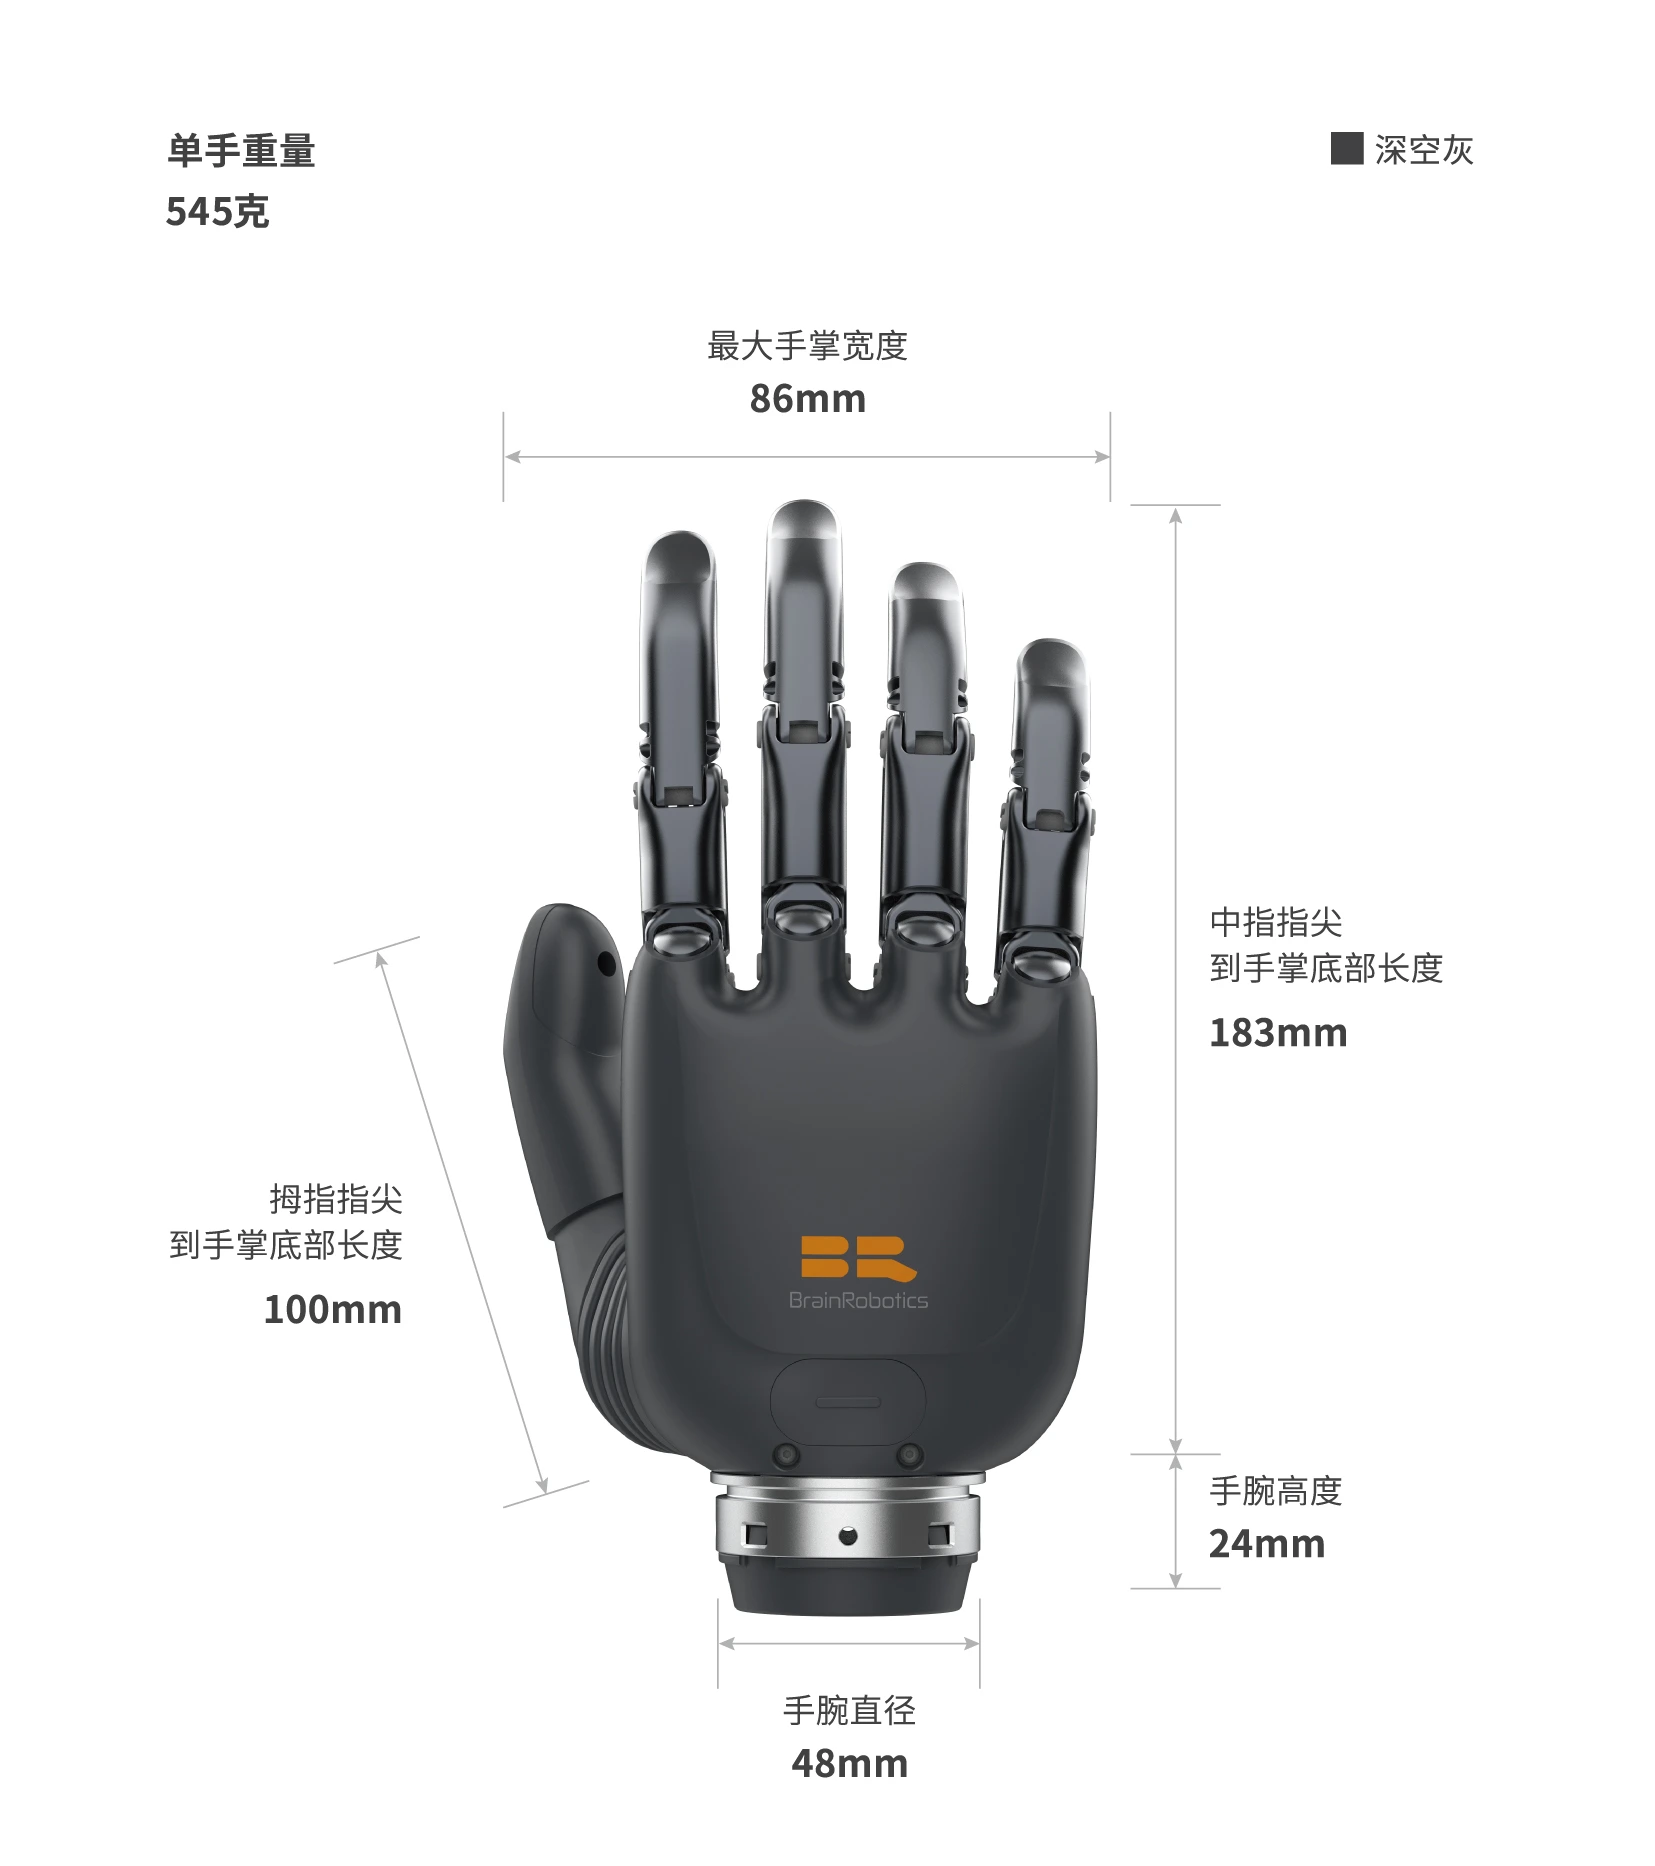
Product Size
Product Parameters
| Product Name | Product Rendering | |||
|---|---|---|---|---|
| Biomimetic Dexterous Hand Revo 1 |  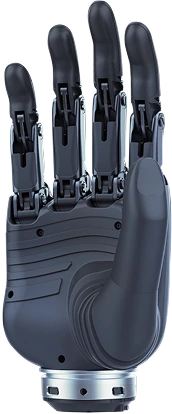 | |||
| Model | BASIC | BASIC TOUCH SKU | ADVANCED | |
| Version Code | MRL1/MRR1 | MTL1/MTR1 | MEL2/MER2 | |
| Operating Parameters | Supply Voltage | 9.5 ~ 28 V | 12 ~ 78 V | |
| Maximum Current | 3 A | 5 A @24V | ||
| Max Opening Distance (Index to Thumb) | 113 mm | |||
| Single-finger Max Pinch Force | 30 N | 20 N | ||
| Five-finger Grip Force | 50 N | |||
| Finger Flexion/Extension Speed | 0.85 s | 0.95 s | ||
| Control Precision | 0.1 mm | |||
| Single-finger Max Payload | 8 kg | |||
| Whole-hand Max Payload | 30 kg | |||
| Finger Service Life | 300,000 cycles | |||
| Operating Temperature | -10℃ - 40℃ | |||
| Hardware Config | Communication Interface | RS485, CAN | RS485 / CAN FD / EtherCAT | |
| Sensor Configuration | Position sensors, Current sensors | |||
| Main Material | Aviation aluminum alloy & Food-grade plastic | |||
| Kinematic Ability | 10 DoF biomimetic joints | |||
| Actuators | 6 precision micro-motors | |||
| Smart Control | Fine manipulation, Stall protection, Shake & Drop protection | |||
| Tactile Sensors | Fingertip Tactile Sensor | / | Measures normal pressure, shear force, force vector, proximity distance | / |
| Measurement Range (Configurable) | 0 - 25 N | |||
| Minimum Resolving Force | 0.1 N | |||
| Measurement Accuracy | 5% FS | |||
| Overload Threshold | ≥50 N | |||
| Proximity Sensing Distance | 0 - 1 cm (Human hand) | |||
| Communication Frequency | ≥50 Hz | |||
Parameter Description
Degree of Freedom Distribution
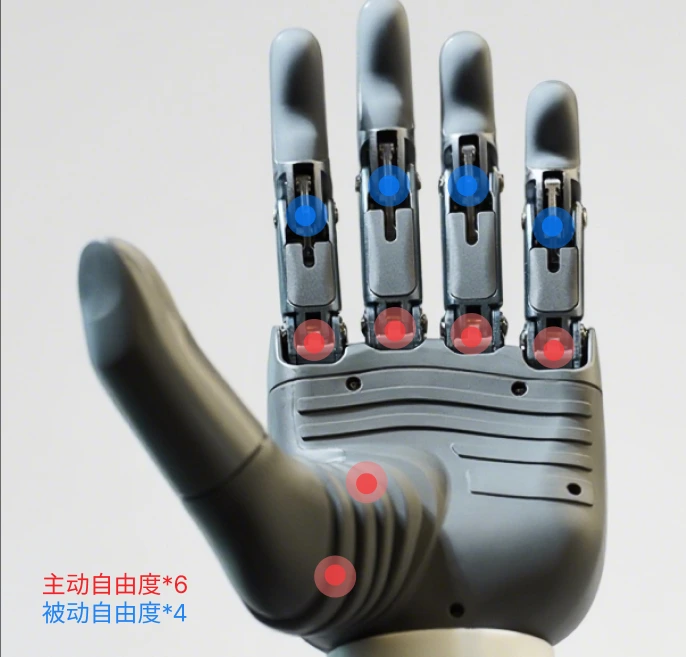
The Revo 1 dexterous hand is equipped with 6 active joints, providing a total of 10 degrees of freedom. The thumb features two active degrees of freedom for abduction/adduction and flexion/extension, while the remaining four fingers each possess one active degree of freedom for flexion/extension and one passive degree of freedom for flexion/extension.
Range of Motion
| Active Joint | Degree of Freedom | Minimum Angle (°) | Maximum Angle (°) |
|---|---|---|---|
| Thumb Flex | Flexion/Extension | 0 | 55 |
| Thumb Aux | Adduction/Abduction | 0 | 90 |
| Index Finger | Flexion/Extension | 0 | 70 |
| Middle Finger | Flexion/Extension | 0 | 70 |
| Ring Finger | Flexion/Extension | 0 | 70 |
| Little Finger | Flexion/Extension | 0 | 70 |
Definition of Hand LED Status
| LED Effect | Description |
|---|---|
| Green flashing | Powering on (reset not completed) |
| Green solid | Normal operation (reset completed) |
| Blue solid | Startup anomaly (unable to boot) |
| Red solid | Error (refer to error messages) |
| Cyan solid | OTA upgrading in progress |
| Orange solid | Power supply voltage too low |
Note: Custom colors and patterns can be configured by the user.
Motor ID and Status
| Motor ID | Description |
|---|---|
| FINGERID_THUMB | Thumb Flex |
| FINGERID_THUMB_AUX | Thumb Aux |
| FINGERID_INDEX | Index Finger |
| FINGERID_MIDDLE | Middle Finger |
| FINGERID_RING | Ring Finger |
| FINGERID_PINKY | Little Finger |
| Motor Status | Description |
|---|---|
| MOTOR_IDLE | Joint Idle |
| MOTOR_RUNNING | Joint Running |
| MOTOR_STALL | Joint Stall |
Grasping Force Settings
| No. | Force Level | Description |
|---|---|---|
| 1 | Small | Low force threshold |
| 2 | Normal | Medium force threshold |
| 3 | Full | High force threshold |
Control Mode Description
| No. | Control Mode | Description |
|---|---|---|
| 1 | Position | Move continuously to the target position until limit or physical stall |
| 2 | Speed | Move continuously at the target speed until limit or physical stall |
Turbo Mode Description
Turbo mode is based on stall detection. When a finger stalls against an object, it pauses for the configured stall duration and then continues gripping at 500 ms intervals. This mode can be used when the hand needs to maintain grip on soft or shifting objects.
Device ID Description
For Revo 1, the default device ID is 1. Users can modify it within the range of 1 - 254. 0 is reserved as the broadcast address.
Description of the Power-on Auto-Calibration Process
Automatic reset upon powering on refers to the dexterous hand automatically executing a position calibration sweep after being powered on. Upon startup, the dexterous hand will search for the starting origin bounds of the fingers, during which all fingers will be set in motion.
- Note 1: During the position calibration sweep, if the dexterous hand is currently holding an object, there is a physical risk of dropping it.
- Note 2: After powering on, position calibration must be completed successfully before normal control commands are permitted.
Communication Interface Description
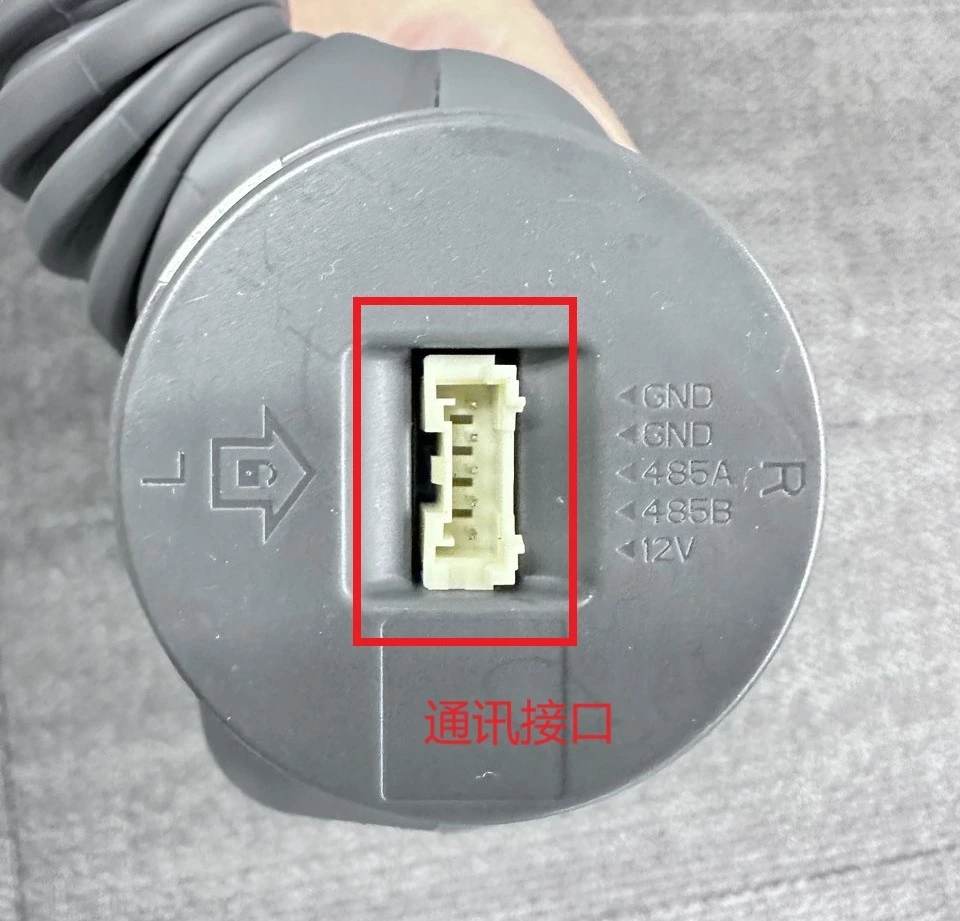
The Revo 1 dexterous hand communicates and is controlled via a standard RS485 serial port. The interface is located under the wrist, and the connector model is PAP-05V-S.