Overview
The BrainCo Revo 3 biomimetic dexterous hand is designed for industrial automation, scientific research, and advanced robotics manipulation. Featuring 21 independently driven motors for 21 fully active degrees of freedom, it delivers high-dexterity multi-finger coordination within a compact, lightweight form factor. Equipped with industrial-grade RS-485, CAN FD, and EtherCAT interfaces, Revo 3 satisfies real-time communication requirements in demanding electromagnetic environments. Complete cross-platform C/C++ and Python SDKs compatible with Linux and Windows streamline development and integration workflows.
Key Features
- 21-DoF Fully Active Biomimetic Architecture: 21 independent motors enable finger opposition, lateral abduction/adduction, and multi-finger coordination for precision manipulation and adaptive grasping. Direct-driven and backdrivable joints provide rapid response and high control density across all finger segments.
- High-Resolution Tactile Sensing: Supports distributed high-sensitivity tactile arrays for real-time contact state and pressure distribution sensing, enabling adaptive grasping of fragile, soft, and irregular objects.
- High Reliability & Industrial Durability: Rated for over 1,000,000 joint flex cycles. Qualified through vibration, impact, payload, temperature extremes, and salt spray testing for continuous, stable operation.
- Standardized Software & Robotics Integration: Comprehensive C/C++ and Python SDKs with ROS support facilitate integration into standard robotics platforms, supported by demo examples for model transfer and algorithm verification.
Product Dimensions
Product Parameters
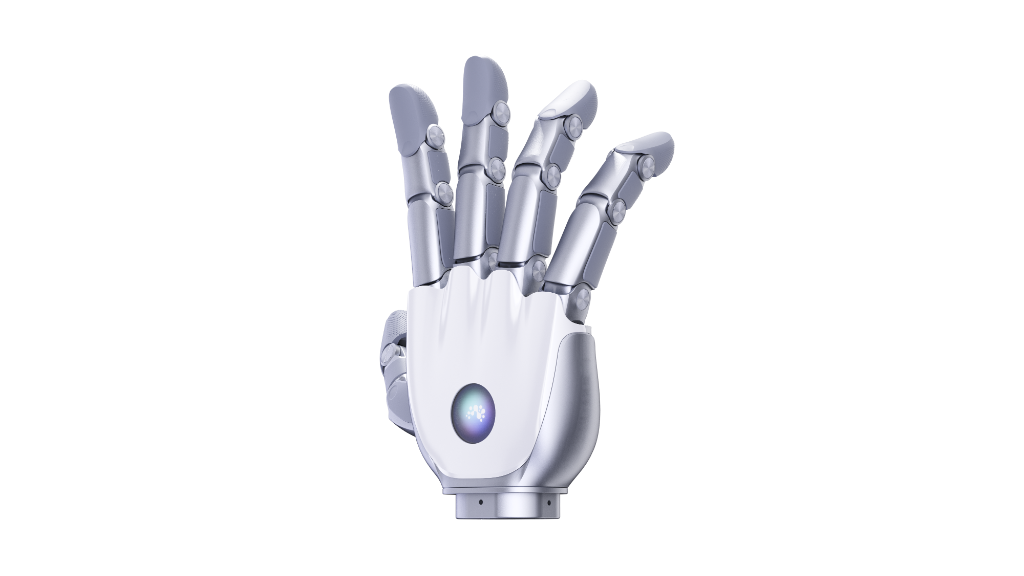 Standard styles: Bionic Silver (supporting Left/Right hands laterality, customizable in bulk)
| Category | Parameter | Revo 3 U21 | Revo 3 U21F | Revo 3 U21T | Revo 3 U21VT |
|---|---|---|---|---|---|
| Degrees of Freedom | Total DoF | 21 (Direct-driven and backdrivable) | 21 (Direct-driven and backdrivable) | 21 (Direct-driven and backdrivable) | 21 (Direct-driven and backdrivable) |
| DoF Distribution | Four fingers × 4 DoF, thumb × 5 DoF | Four fingers × 4 DoF, thumb × 5 DoF | Four fingers × 4 DoF, thumb × 5 DoF | Four fingers × 4 DoF, thumb × 5 DoF | |
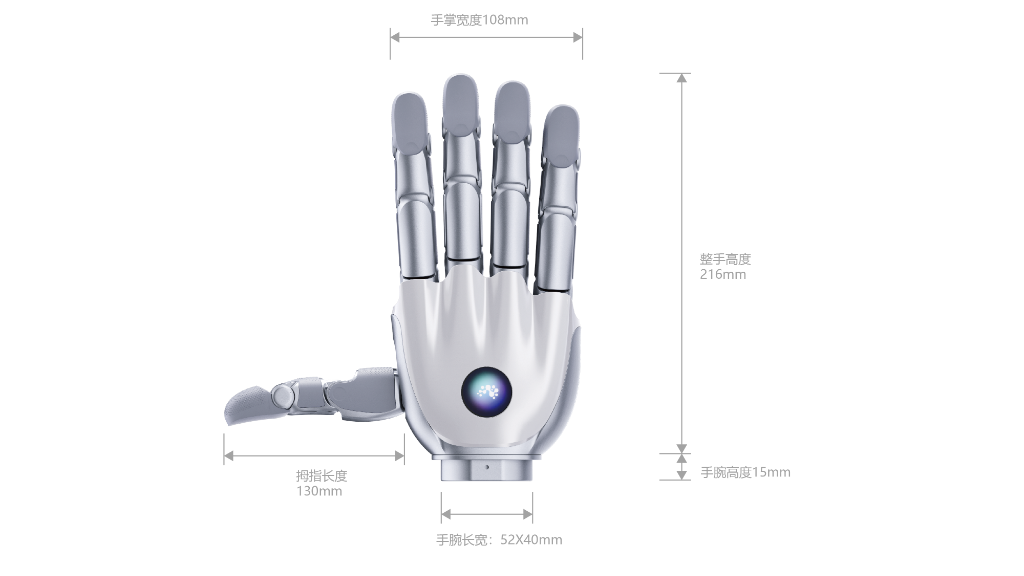
| Dimensions | Hand Dimensions | 216 × 108 × 50 mm | 216 × 108 × 50 mm | 216 × 108 × 50 mm | 216 × 108 × 50 mm |
| Operating Parameters | Supply Voltage | 16–85 V | 16–85 V | 16–85 V | 16–85 V |
| Max Current | 10 A (24 V) | 10 A (24 V) | 10 A (24 V) | 10 A (24 V) | |
| Max Active Grip Force | ≥100 N | ≥100 N | ≥100 N | ≥100 N | |
| Max Fingertip Pinch Force | ≥25 N | ≥25 N | ≥25 N | ≥25 N | |
| Total Hand Payload | 20 kg | 20 kg | 20 kg | 20 kg | |
| Four-finger Payload | 5 kg | 5 kg | 5 kg | 5 kg | |
| Repeatability | 0.1° | 0.1° | 0.1° | 0.1° | |
| Joint Open/Close Time | 0.33 s | 0.33 s | 0.33 s | 0.33 s | |
| Motion Capabilities | Motion Ability | Full score on the Kapandji opposition test Covers 33 grasp types (Feix GRASP taxonomy) | Full score on the Kapandji opposition test Covers 33 grasp types (Feix GRASP taxonomy) | Full score on the Kapandji opposition test Covers 33 grasp types (Feix GRASP taxonomy) | Full score on the Kapandji opposition test Covers 33 grasp types (Feix GRASP taxonomy) |
| Min Grasping Diameter | 10 mm | 10 mm | 10 mm | 10 mm | |
| Max Grasping Diameter | 150 mm | 150 mm | 150 mm | 150 mm | |
| Hardware Configuration | Communication Interface | EtherCAT / CAN FD / RS-485 | EtherCAT / CAN FD / RS-485 | EtherCAT / CAN FD / RS-485 | EtherCAT / CAN FD / RS-485 |
| Communication Frequency | 500 Hz | 500 Hz | 500 Hz | 500 Hz | |
| Sensors | IMU (Mainboard), Temperature (Mainboard) | IMU (Mainboard), Temperature (Mainboard) | IMU (Mainboard), Temperature (Mainboard) | IMU (Mainboard), Temperature (Mainboard) | |
| Tactile Module | Tactile Distribution | / | Fingertip tactile | Full-palm tactile | Full-palm tactile |
| Tactile Type | / | Fingertip three-axis force | Full-palm piezoresistive array | Palm piezoresistive array + fingertip vision-tactile | |
| Array Taxels | / | 5 modules (three-axis force) | 451 points (piezoresistive) | 336 points (piezoresistive) + 2000 markers (vision-tactile) | |
| Force Range | / | 0–20 N | 0–20 N | 0–20 N | |
| Resolution | / | 0.01 N | 0.01 N | 0.01 N |
Parameter Description
Degrees of Freedom Distribution
Revo 3 features 21 fully active, independently driven degrees of freedom: five in the thumb and four in each of the index, middle, ring, and pinky fingers. Every joint can be controlled independently, enabling opposition, pinch, coordinated grasping, and fine manipulation.
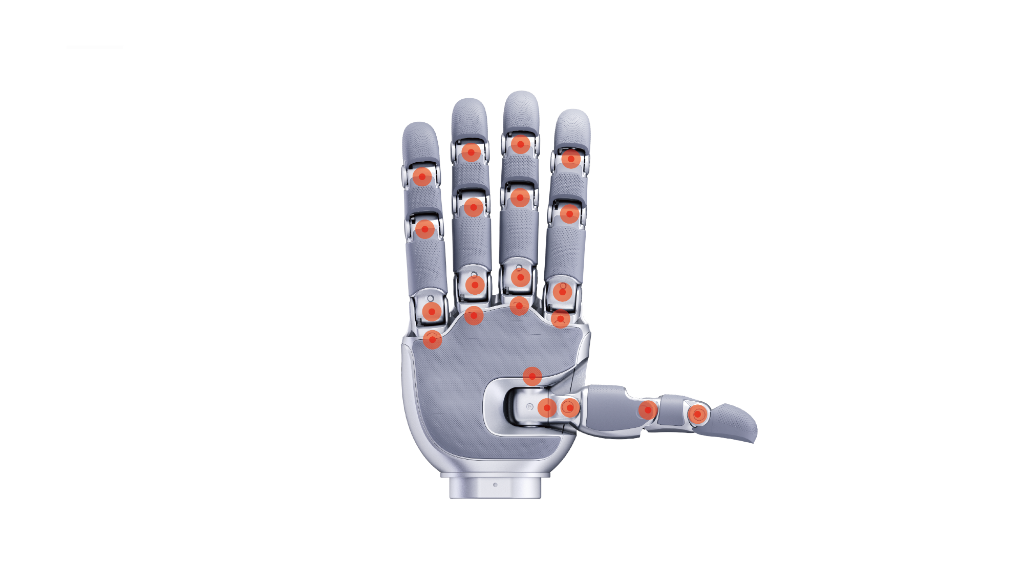 Physical distribution diagram of the 21 fully active independently driven degrees of freedom (motors) of the Revo 3 smart dexterous hand
Joint Motion Range
The physical achievable joint motion range (corresponding to the physical float parameters in the SDK interface) for each joint is listed in the table below:
| Active Joint | Joint Motion Range | Min Angle | Max Angle |
|---|---|---|---|
| Thumb | CMC Abd (Carpometacarpal Abduction), J19 | 0° | 110° |
| CMC Rotation (Carpometacarpal Rotation), J20 | 0° | 105° | |
| CMC Flex — Thumb base flexion/extension, J16 | 0° | 75° | |
| MCP — Thumb middle joint flexion/extension, J17 | -10° | 90° | |
| IP — Thumb terminal joint flexion/extension, J18 | -20° | 90° | |
| Index | Abd (Abduction/Adduction) | -10° | 30° |
| MCP Flex (Metacarpophalangeal Flexion) | -5° | 90° | |
| PIP Flex (Proximal Interphalangeal Flexion) | -10° | 90° | |
| DIP Flex (Distal Interphalangeal Flexion) | -20° | 90° | |
| Middle | Abd (Abduction/Adduction) | -20° | 25° |
| MCP Flex (Metacarpophalangeal Flexion) | -5° | 90° | |
| PIP Flex (Proximal Interphalangeal Flexion) | -10° | 90° | |
| DIP Flex (Distal Interphalangeal Flexion) | -20° | 90° | |
| Ring | Abd (Abduction/Adduction) | -25° | 20° |
| MCP Flex (Metacarpophalangeal Flexion) | -5° | 90° | |
| PIP Flex (Proximal Interphalangeal Flexion) | -10° | 90° | |
| DIP Flex (Distal Interphalangeal Flexion) | -20° | 90° | |
| Pinky | Abd (Abduction/Adduction) | -30° | 10° |
| MCP Flex (Metacarpophalangeal Flexion) | -5° | 90° | |
| PIP Flex (Proximal Interphalangeal Flexion) | -10° | 90° | |
| DIP Flex (Distal Interphalangeal Flexion) | -20° | 90° |
Use J indices for commands and feedback, and device-reported limits from hand.config.snapshot().
Device ID Specifications
In the RS485 bus network topology, the default Left Hand ID for both Revo 2 and Revo 3 dexterous hands is 126, the default Right Hand ID is 127, and the Broadcast ID is 0.
In multi-device topologies, developers can configure unique IDs to identify and control the left and right hands separately. Sending instructions to Broadcast ID 0 will control all dexterous hands on the bus simultaneously.
Power-On Reset & Calibration
Power-on self-reset refers to the dexterous hand automatically executing physical position calibration upon power-on. The system will search for the starting position of each finger, and all fingers will open during this period.
⚠️ Critical Safety Notes for Power-On Calibration
- Note 1 (Drop Risk): During the process of position calibration, if the hand is holding any object, there is a potential risk of the object falling.
- Note 2 (Control Prerequisite): After the hand is powered on, a position calibration must be executed once before it can be controlled normally.
Communication Interface
The Revo 3 dexterous hand communicates through RS485, CAN FD, or EtherCAT interfaces.
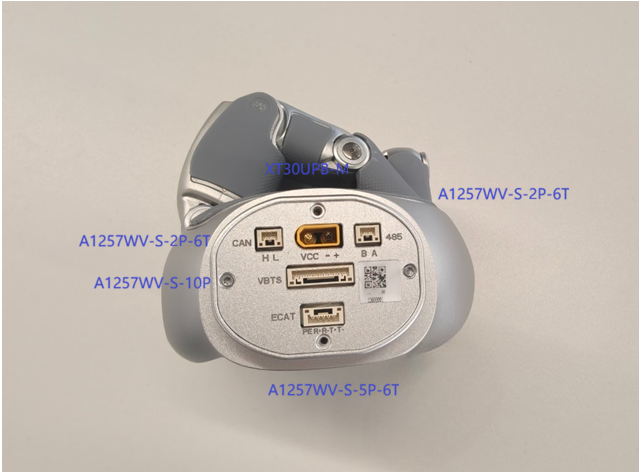
Physical Connector Specifications
| Interface | Connector Model | Description |
|---|---|---|
| 485 | A1257WV-S-2P-6T | RS485 communication interface |
| CAN FD | A1257WV-S-2P-6T | CAN FD communication interface |
| EtherCAT | A1257WV-S-5P-6T | EtherCAT communication interface |
| VCC | XT30UPB-M | Main power supply interface |
| VBTS | A1257WV-S-10P | Tactile/sensor data transmission expansion interface |
When performing physical wiring and debugging, please pay close attention to the following guidelines:
🔌 Power Supply & Bus Security
- Power Budget: Since the Revo 3 integrates 21 independent motors, instantaneous current can be high under heavy loads or when multiple fingers are gripping. Use a stable 24V DC power supply with a power rating of at least 100W to reduce voltage drop risk.
- Bus Wiring: At 5M baud rate, use shielded twisted pair cables for the RS485 bus and keep the wiring length as short as possible to reduce signal reflection and noise.